Edge Intelligence and Real-Time Decision Making in Autonomous Vehicles
Autonomous vehicles are moving from experimental technology toward practical deployment across passenger transport, logistics, public mobility and industrial operations. Their ability to operate safely depends on processing enormous amounts of information from cameras, radar, lidar, GPS, vehicle systems and connected infrastructure. Traditional cloud computing can support many of these functions, but sending every piece of information to a distant data centre can introduce delays and increase dependence on network connectivity.
This is where edge computing applications in autonomous vehicles become increasingly important. Edge computing allows data to be processed closer to where it is generated, reducing the distance information must travel before software can respond. For an autonomous vehicle, this can support faster perception, decision-making and control while reducing the need to continuously transmit raw sensor information to the cloud.
Why real-time processing matters
An autonomous vehicle continuously observes its surroundings. A pedestrian may enter a road, another vehicle may suddenly brake, traffic signals may change or road conditions may deteriorate within seconds. The vehicle must identify these events and determine an appropriate response.
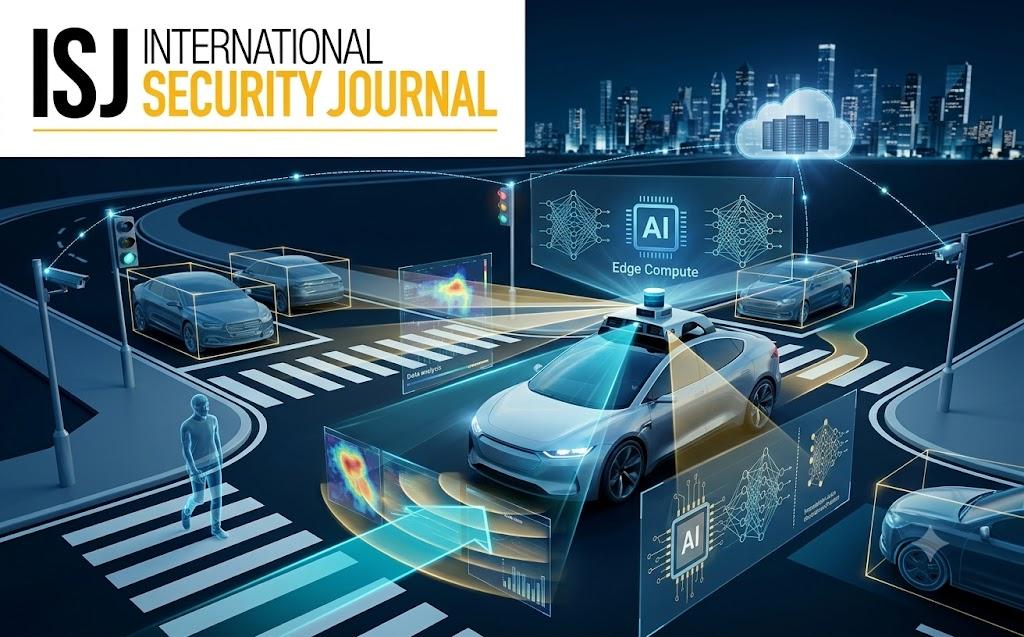
Cloud-based processing can provide substantial computational resources, but network latency can become a concern when decisions are time-critical. An edge architecture can place processing capabilities inside the vehicle or at nearby roadside infrastructure. This means important information can be analysed locally instead of depending entirely on a remote platform.
For example, a vehicle's onboard computing system can analyse camera and lidar data to identify obstacles. Rather than uploading all raw video to a cloud server, the vehicle can process the information locally and transmit only selected events or summaries.
Sensor data and local analytics
Modern autonomous vehicles generate huge volumes of sensor data. Cameras produce continuous video streams, lidar creates three-dimensional environmental representations and radar detects objects and movement patterns.
Processing all this information centrally would require considerable bandwidth. Edge computing reduces this burden by filtering and analysing information near its source.
One of the most valuable edge computing applications in autonomous vehicles is therefore local sensor fusion. Different sensors can be combined to create a more reliable representation of the environment. If a camera identifies an object while radar detects its movement and lidar estimates its distance, the vehicle's edge processor can combine those observations almost immediately.
This approach can improve situational awareness without requiring every sensor output to travel to a remote server.
Supporting autonomous decision-making
Autonomous driving systems must move beyond identifying objects. They also need to predict behaviour and choose suitable actions.
An edge computing platform can run machine-learning models that evaluate traffic conditions, road geometry, object movement and vehicle position. The system may determine whether to slow down, change lanes, maintain its trajectory or stop.
Keeping these calculations close to the vehicle can provide a more predictable response time. This is particularly useful in environments where connectivity is unreliable, such as tunnels, rural roads or areas affected by network congestion.
Edge and cloud working together
Edge computing does not necessarily replace cloud infrastructure. Instead, the two can work together.
The vehicle can handle urgent functions locally while cloud systems manage less time-sensitive workloads. For instance, immediate collision avoidance can remain on the vehicle, while historical driving information can be uploaded for fleet analysis, software improvement or infrastructure planning.
This hybrid architecture represents one of the most practical edge computing applications in autonomous vehicles because it combines local responsiveness with the wider analytical capabilities of cloud platforms.
Security considerations
More distributed computing also creates new security responsibilities. Autonomous vehicles contain software, sensors, communications interfaces and computing resources that may become targets for attackers.
Edge systems therefore require strong authentication, secure software updates, encryption, access controls and continuous monitoring. Compromising an edge processor could potentially affect vehicle behaviour, making cybersecurity a safety issue as well as an information-security concern.
Organisations deploying autonomous fleets should also consider how data is collected, retained and shared. Local processing can reduce unnecessary transmission of sensitive information, but it does not eliminate privacy risks.
The role of roadside edge infrastructure
Edge computing can extend beyond the vehicle itself. Roadside units can process information from multiple vehicles and infrastructure sensors. A roadside edge node might identify congestion, detect an obstruction or coordinate information about an approaching emergency vehicle.
This creates another category of edge computing applications in autonomous vehicles, where local infrastructure acts as an intermediary between vehicles and central cloud services.
For example, an intersection could have an edge processor that receives information from traffic cameras, connected vehicles and signal controllers. It could then distribute relevant information to approaching autonomous vehicles.
Future development
As autonomous vehicles become more sophisticated, edge computing is likely to become increasingly integrated into vehicle architecture. Future systems may combine high-performance processors, artificial intelligence accelerators and specialised safety systems to analyse complex environments locally.
The emphasis will not simply be on processing speed. Reliability, resilience, cybersecurity and predictable performance will be equally important.
For security professionals and technology leaders, organisations such as International Security Journal can provide useful industry perspectives as connected mobility and intelligent infrastructure evolve.
Ultimately, the strongest autonomous vehicle architectures are likely to use a layered approach. Critical decisions can be processed locally, nearby infrastructure can provide contextual information, and cloud platforms can support long-term analysis. This combination can help autonomous vehicles respond quickly while maintaining access to broader computational resources.

 English
 Arabic
 French
 Portuguese
 Deutsch
 Turkish
 Dutch
 Italiano
 Russian
 Romaian
 Portuguese (Brazil)
 Greek